Lê Tuân (Tuan Le)
3D perception for autonomous driving and robotics
I am a postdoctoral researcher at the Heudiasyc Laboratory, University of Technology of Compiègne (UTC), France, working with Julien Moreau and Franck Davoine. My research covers open-vocabulary 3D object detection from LiDAR and camera data and, more recently, event-based vision with binary neural networks.
I received my PhD from UTC (Roberval Laboratory) in 2024, advised by Vu Hai Canh and Zohra Cherfi-Boulanger, with the thesis "Semi-supervised Deep Learning for Robust Anomaly Detection in Smart Manufacturing Systems".
I am currently looking for research and engineering positions in 3D perception and computer vision.
Research
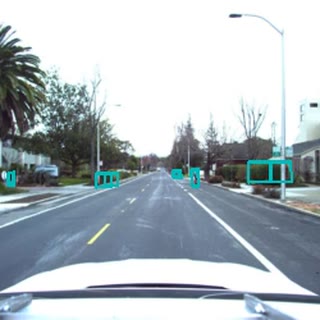
Ongoing research, 2026
video demo
Producing 3D bounding boxes in LiDAR point clouds without human 3D labels, by combining 2D vision foundation models with LiDAR geometry. Any object category that can be named in text can be annotated.
News
- Jul 2026 Started a postdoc on REVE-BNN (Robotic Event Vision through Efficient BNNs): event cameras and binary neural networks.
- Mar 2025 Started a postdoc on the Annapolis project, focusing on 3D object detection.